 Coach
Round-trip triangulation estimates where a server is from round trips measured to it from probes at known places: each round trip bounds the distance (light cannot cover more than half of it in glass) and, divided by a route factor, estimates it; the estimate is the point whose distances best agree with those estimates.
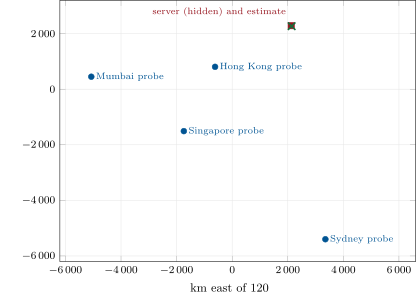
fig_find.py, nw_find.triangulate_example().