全部书籍

专业

应用 关于 Coach 登录 开始阅读

书籍暂未推出简体中文版——当前显示英文版。

Physics · 术语表

什么是 Moment about a point; about an axis?

Definition 15.1 University Physics — Year 1 · 第 15 章 — Angular Momentum

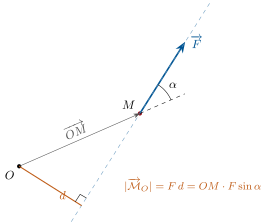
The moment (or torque) about a point OO of a force F→\vect F applied at MM is the vector

M→O(F→)=OM→∧F→(N m),\vect{\mathcal M}_O(\vect F) = \vect{OM}\wedge\vect F \qquad (\mathrm{N}\,\mathrm{m}),

perpendicular to the plane of OM→\vect{OM} and F→\vect F, of norm OM⋅Fsin⁡α=F dOM\cdot F\sin\alpha = F\,d, where dd — the lever arm — is the distance from OO to the line of action of F→\vect F. The moment about an oriented axis Δ\Delta (unit vector e→Δ\vect e_\Delta) through OO is the scalar MΔ=M→O⋅e→Δ\mathcal M_\Delta = \vect{\mathcal M}_O\cdot\vect e_\Delta, independent of the choice of OO on Δ\Delta; it vanishes if F→\vect F is parallel to Δ\Delta or meets it. Two opposite forces on different lines of action form a couple, whose moment F→∧AB→\vect F\wedge\vect{AB} is the same about every point.

The moment of F about O: the cross product OM F, of norm F\,d with d the distance from O to the line of action (the lever arm), directed perpendicular to the figure — here toward the reader.
The moment of F→\vect F about OO: the cross product OM→∧F→\vect{OM}\wedge\vect F, of norm F dF\,d with dd the distance from OO to the line of action (the lever arm), directed perpendicular to the figure — here toward the reader.

示例

Example 15.2 (The door)

A 20 N20\,\mathrm{N} push perpendicular to a door at 0.80 m0.80\,\mathrm{m} from the hinges has moment 16 N m16\,\mathrm{N}\,\mathrm{m} about the hinge axis; the same push at 0.10 m0.10\,\mathrm{m}, 2 N m2\,\mathrm{N}\,\mathrm{m}; along the door (line of action through the hinges), zero. The hinge’s own reaction, meeting the axis, has no moment about it: that is what makes the axis the natural place to take moments.

Example 15.6 (The pendulum by moments)

Simple pendulum, axis Δ\Delta through the pivot perpendicular to the plane of swing: LΔ=mℓ2θ˙L_\Delta = m\ell^2\dot\theta; the tension meets the axis (no moment), the weight’s moment is −mgℓsin⁡θ-mg\ell\sin\theta (lever arm ℓsin⁡θ\ell\sin\theta, restoring). The theorem gives mℓ2θ¨=−mgℓsin⁡θm\ell^2\ddot\theta = -mg\ell\sin\theta, the equation of Example 12.12 without ever writing the tension — the chief advantage of moments: forces through the axis disappear.

Example 15.10 (The skater)

Arms out, a skater’s body has J≈4 kg m2J \approx 4\,\mathrm{kg}\,\mathrm{m}^{2} plus two 3 kg3\,\mathrm{kg} arms at 0.8 m0.8\,\mathrm{m}: J1=4+2×3×0.64=7.8 kg m2J_1 = 4 + 2 \times 3 \times 0.64 = 7.8\,\mathrm{kg}\,\mathrm{m}^{2}. Arms in (0.2 m0.2\,\mathrm{m}): J2=4.2 kg m2J_2 = 4.2\,\mathrm{kg}\,\mathrm{m}^{2}. The ice’s reaction and the weight have no moment about the vertical axis: JωJ\omega is conserved and the spin rate rises by J1/J2=1.85J_1/J_2 = 1.85 — from 22 to 3.73.7 turns per second — while the kinetic energy rises by the same factor, paid by the muscles pulling the arms in.

在原文中阅读 →